What this page is about
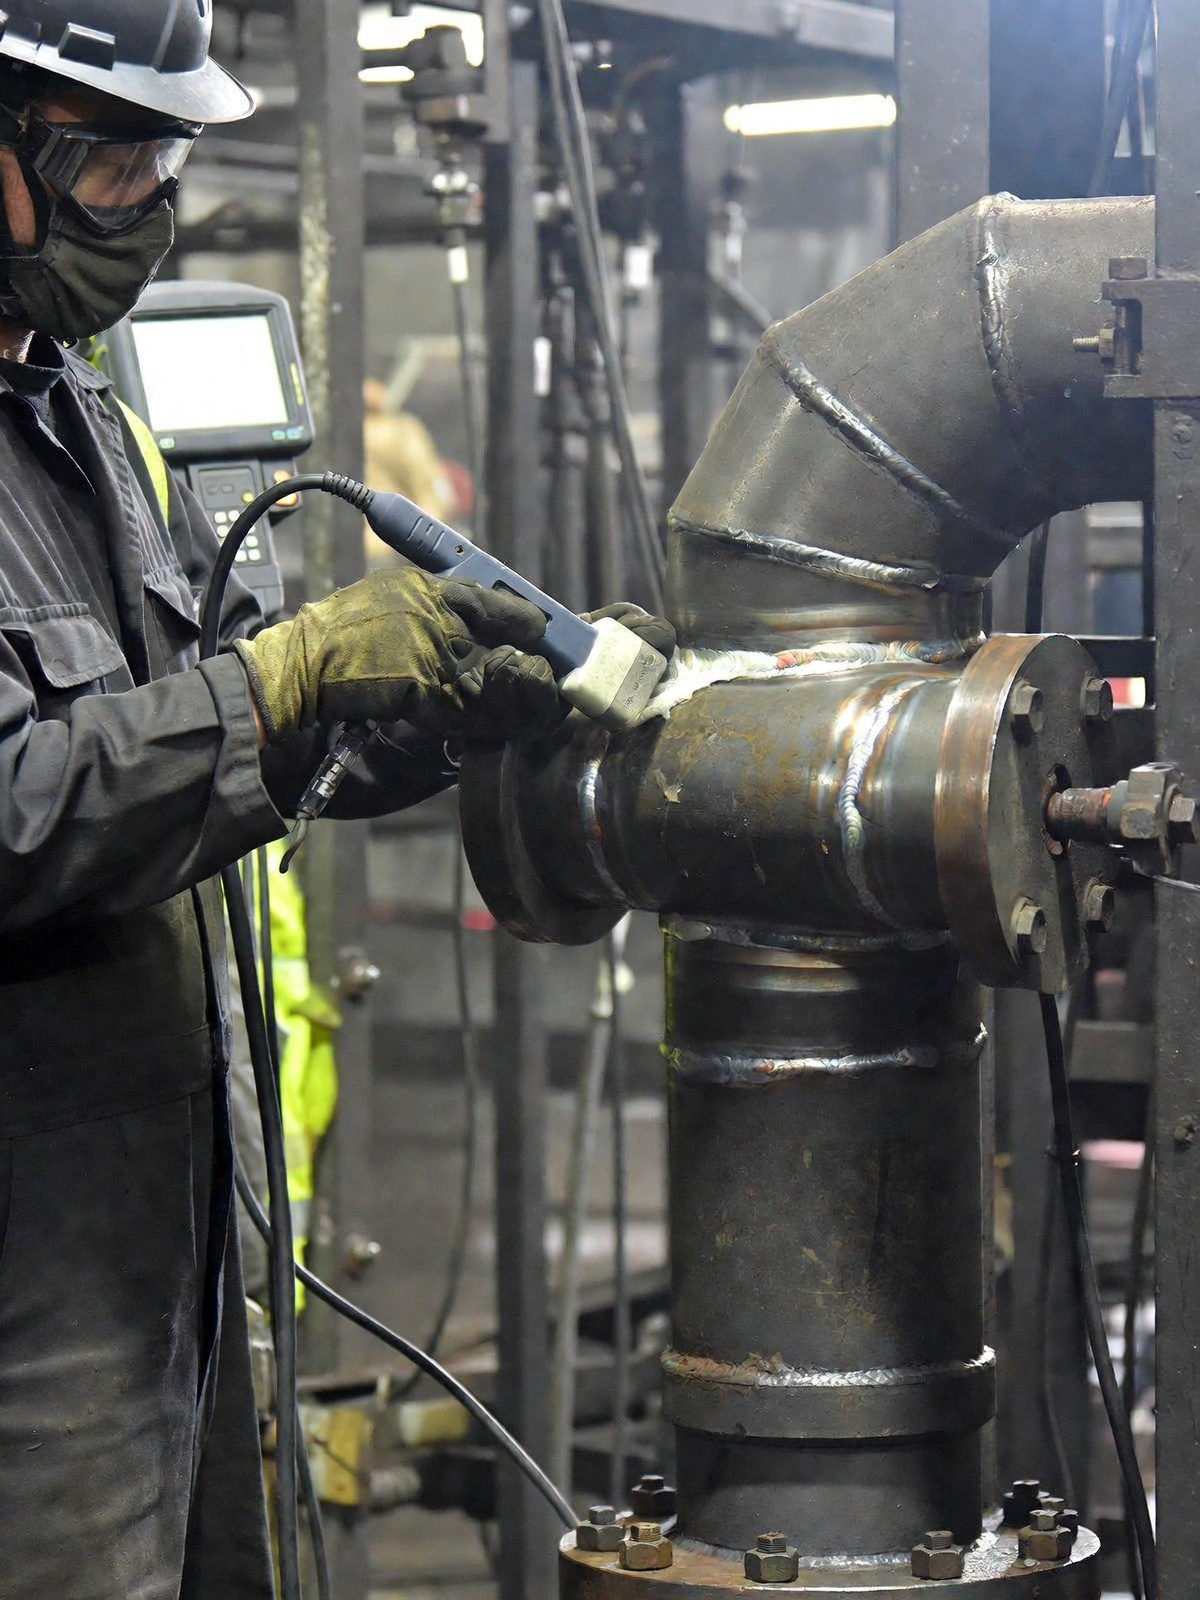
Manual weld inspection still depends on the inspector’s technique. On long seams, nozzles and curved joints, probe orientation and coupling drift. Quality varies between shifts. The report is often disconnected from where the probe actually was.
ROBINSPECT is a robotic NDT integrator: we do not sell a robot. We design the inspection engineering — 3D geometry, trajectory on the weld, probe at the surface normal, coupling, and synchronized UT acquisition (PAUT and TFM in PoC).
The workflow
- Scan the part. About 30 seconds of 3D scan on the filmed part; on a production part, expect a few minutes.
- Generate a tool path on the weld, in a few seconds.
- Set up the cell once — then the path is replayable.
- Acquire UT along that path (PAUT or TFM in a PoC). Contact-UT acquisition is under a minute on the filmed coupon — not PAUT/TFM, and not a long part.
Once the cell is taught: about 30 minutes for the full contact-UT cycle, measured on the filmed part only. Not a guaranteed turnaround, and not a figure for PAUT or TFM. A Level 2 inspector still signs off acquisition and interpretation.
Vendor-agnostic on purpose
The value is the workflow, not a locked hardware stack. Multi-robot, multi-sensor. If you already have a PAUT instrument or a 6-axis arm, we integrate around it.