The geometry problem
Aerospace and space structures are rarely flat. Manual UT on a curved panel is slow, tiring, and hard to document. A grid that doesn’t follow the surface lifts the probe as the radius changes.
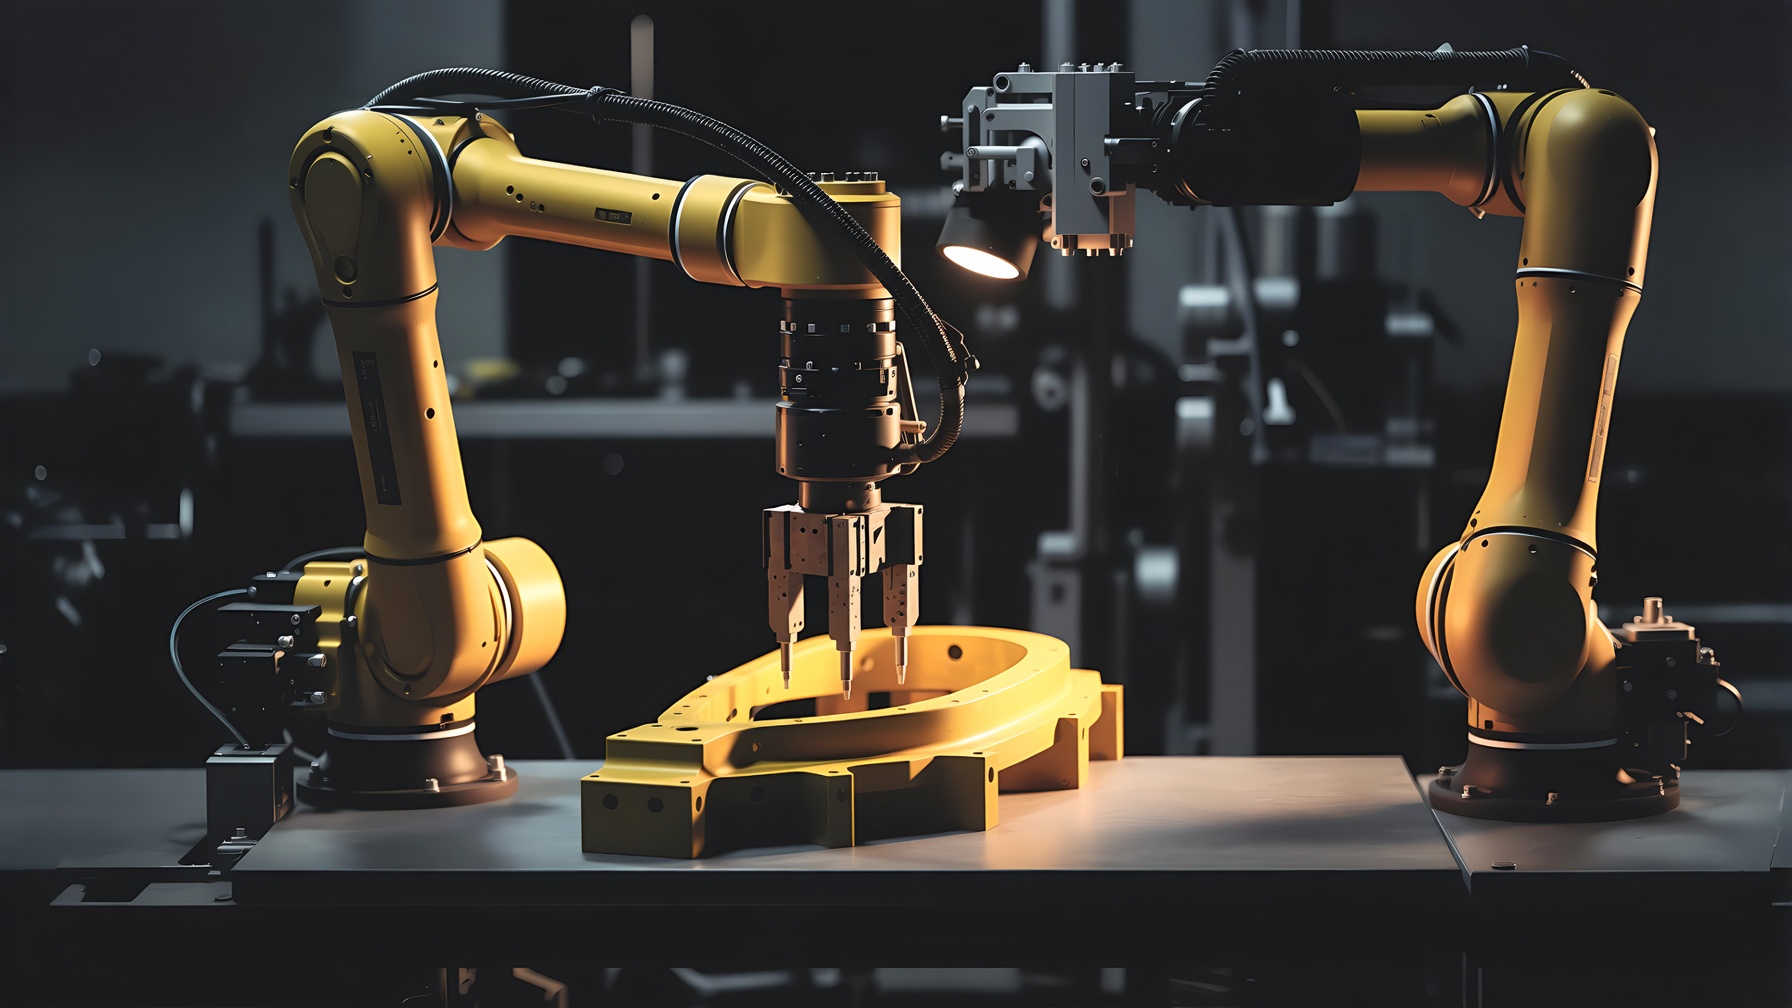
ROBINSPECT builds surface-following paths: 3D scan, mesh, trajectory with the probe at the surface normal, then ultrasonics synced with the robot: contact UT, with PAUT and TFM to validate in a PoC. The same idea as a skilled Level 2, without operator-to-operator variability.
What we integrate
- 6-axis motion, multi-brand — vendor-agnostic on the arm.
- Ultrasonic stack of your choice, the one you already run or one we integrate with you: UT, PAUT, TFM.
- Data tied to robot position, so the report follows the trajectory, not a stack of screenshots.
We are an integrator and an inspection-engineering shop, not a robot OEM. The cell is designed around the part, including access, fixtures and HSE on the shop floor.
Once the cell is taught: about 30 minutes for the full contact-UT cycle, measured on the filmed part only. Not a guaranteed turnaround, and not a figure for PAUT or TFM. A Level 2 inspector still signs off acquisition and interpretation.