A modular robotic
inspection platform.
Integrator, not a robot OEM. We wire path planning, advanced ultrasonics, and a data layer into one cell — without locking you to a single brand.
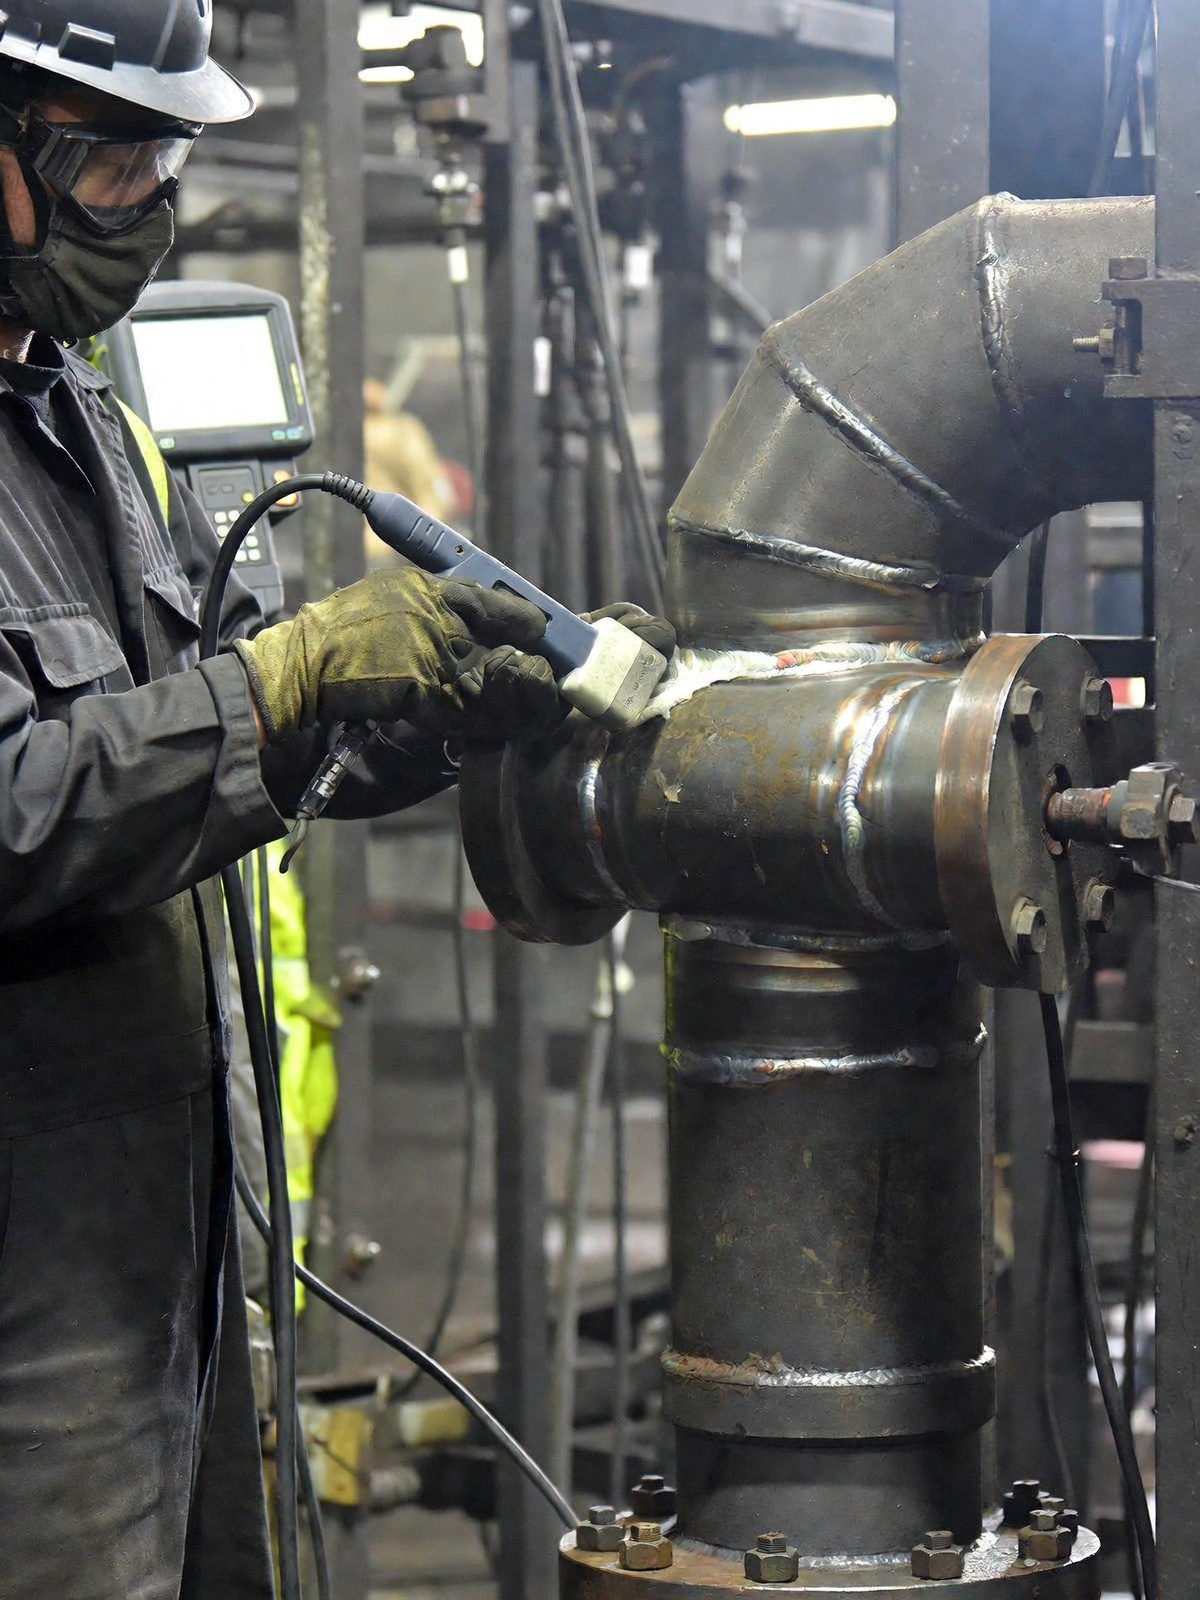
Too manual.
Too variable.
Too hard to scale.
Why NDT automation is critical on complex geometries: the industry still depends on the gesture of the operator.
High operator dependency
Inspection quality still varies significantly between operators. Complex geometries make consistent probe orientation and coupling extremely difficult to repeat.
Cost, time & scalability
Long inspection cycles, production downtime, and a growing shortage of qualified Level 2/3 experts create bottlenecks for critical assets.
Traceability & audit burden
Manual documentation is slow, error-prone and often disconnected from the actual inspection data and robot path.
Safety & access constraints
Many high-value inspections occur in confined, radiological or hazardous environments where manual execution carries high HSE cost.
A modular, vendor-agnostic robotic inspection platform
We integrate the best available hardware into coherent inspection workflows — without locking you into a single robot or sensor brand. Integrator, not a robot OEM. Chain: scan → planning → robot program + UT acquisition.
Path planning
TrajTool plans the ultrasonic probe path from the part geometry: where the tool must travel on the surface, with a stable orientation. It does not drive the robot arm — the robot program runs in the controller. Linking ultrasonic acquisition to motion is a separate layer in the cell. Path planning, robot execution, and UT sync are three jobs; TrajTool owns the first.
Advanced NDT integration
UT, PAUT, TFM with stable coupling. Linking ultrasonic acquisition to motion is a separate sync layer in the cell — distinct from path planning. Hardware-agnostic by design.
Software & data layer
Direction · not live · Exploration
Digital inspection workflows, robot–NDT sync, reporting and traceability from geometry to report — explored with partners. Not a live product layer today. Live path: TrajTool + filmed contact UT cell.